Hi, I'm
Sudhansh Peddabomma
I'm a software engineer in San Francisco who loves learning and wandering into new fields. I enjoy connecting ideas across them, from 3D vision and imaging to generative AI, and turning them into things people actually use.
I studied Computer Science at IIT Bombay, with a minor in Entrepreneurship, and at UC San Diego. I write long notes about whatever I'm learning. Say hi if you want to talk research, startup ideas, or sitcoms.
01
Projects
All projects →Dense 3D reconstruction
3D Reconstruction
Perception for Home Robot
Experimenting with various NeRF and Gaussian Splatting based SLAM algorithms to build a real-time 3D reconstruction of the environment. The methods used include NeRF-SLAM, Nice SLAM, Mip-NeRF and Splatam.
Abstract → generate → verify
Generative AI
MathPrompter++
MathPrompter++ improves the reasoning capabilities of LLMs on numerical problems with robustness by embedding zero-shot CoT in a former Microsoft Research paper - MathPrompter ICLR 2023. The method improves the accuracy while reducing the hallucinate rate. Furthermore, I compiled a new dataset DiverseMath that serves as a better benchmark for reasoning in numerical problems.
DrawingML ⇄ rendered slide
Open Source
ooxml (open source)
Contributions to ooxml, an open-source TypeScript engine and set of browser viewers for Office files, focused on editing fidelity, real-time collaboration, cross-framework parity and performance.
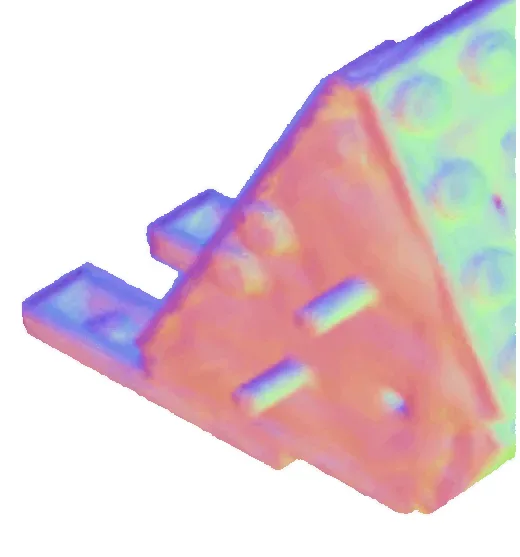
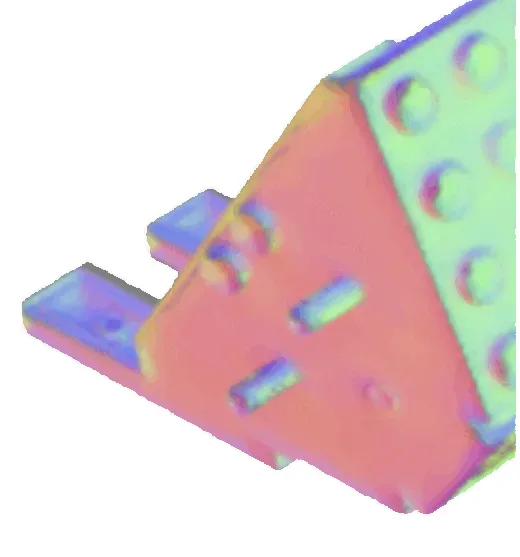 Normal map · detail
3D Reconstruction
Inverse Rendering with 2D Gaussian Splatting
Developed a novel framework in CUDA for inverse rendering using 2D Gaussian splatting. Achieved state-of-the-art results gaining 15% lower normal map error, and obtained more consistent relighting results.
TODOs → today’s journal
Self/Research
VSCode Journal Plugin
VS Code all-in-one journal plugin, combining automated TODO extraction, daily notes, task syncing, file tagging, and natural language support for seamless task management and note-taking
 M = L + S
Statistical Image Processing
Low Rank Matrix Recovery
A in-depth analysis of problem formulations for low-rank matrix recovery such as Robust Principal Component Pursuit, and algorithms such as ALM and Dual Optimization. Extended the approach to applications such as Foreground-Background separation in videos.
02
Publications
All publications →Identification and Correction of Permutation Errors in Compressed Sensing-Based Group Testing
Planning for Tabletop Object Rearrangement
OpenAI GPT-5 outperforms o3 with 83% correctness, and Glean customers can put it to work today
How Digital Twins Accelerate AI Model Deployment
03
News
All news →- Nov 2026
Reviewed papers for ICASSP 2027.
- Dec 2025
Reviewed papers for ICASSP 2026.
- Aug 2025
Judged HackGT 12.
- Aug 2025
Co-authored Glean’s GPT-5 launch evaluation.
- May 2025
Co-wrote How Digital Twins Accelerate AI Model Deployment for Autodesk Research.